Deception-Resistant AI
PI: Zachary Sunberg
- Optimal control and MDP-based deep reinforcement learning (RL) do not reason about active deception.
- Game theory provides mathematical tools and algorithms (e.g. DeepStack AI for Poker).
- Our task: extend these game-theory concepts to autonomous aerospace systems ("drone poker").
How can AI systems resist deception by other agents and uncertainty in nature?
Funding: ONR Science of Autonomy "DECODE-AI" Project
Project 1: Combining robotic and game-theoretic uncertainty representations
Project 2: Neural networks for multi-modal continuous policies.
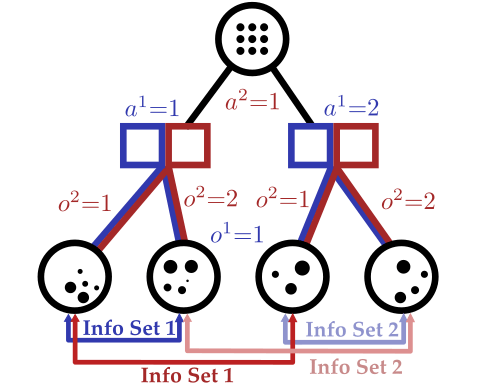
Particle filters from robotics
Information sets from game theory
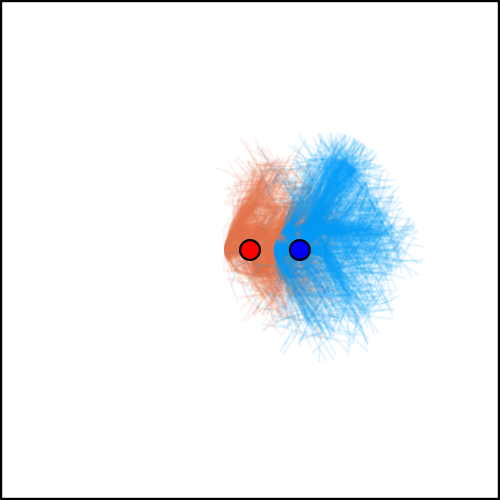
[Becker & Sunberg AAMAS '25 Ext. Abs.]
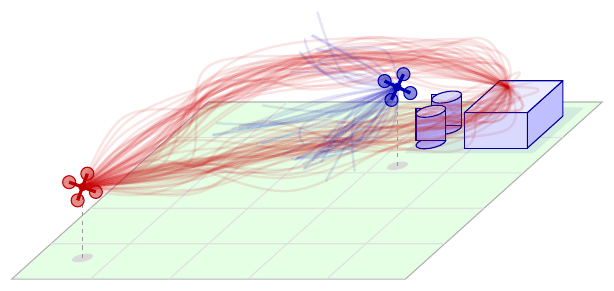
Example: Drone defense - how do we calculate deceptive trajectories and counter them?
Resulting stochastic discrete policies
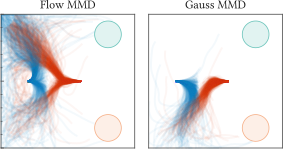
Traditional Gaussian policies are unimodal and exploitable
Flow-Matching magnetic mirror descent produces multimodal unexplotable policies
[Becker & Sunberg AAMAS '27 (Under Review)]